
🌱 𝗙𝗿𝗼𝗺 𝘁𝗵𝗲 𝗟𝗮𝗯 𝘁𝗼 𝘁𝗵𝗲 𝗙𝗶𝗲𝗹𝗱, 𝗨𝗻𝗱𝗲𝗿𝘀𝘁𝗮𝗻𝗱𝗶𝗻𝗴 𝘁𝗵𝗲 𝗘𝗻𝘃𝗶𝗿𝗼𝗻𝗺𝗲𝗻𝘁 𝗕𝗲𝗳𝗼𝗿𝗲 𝗕𝘂𝗶𝗹𝗱𝗶𝗻𝗴 𝗳𝗼𝗿 𝗜𝘁.
After working on the vision and perception side of our 𝗔𝘂𝘁𝗼𝗻𝗼𝗺𝗼𝘂𝘀 𝗔𝗴𝗿𝗶-𝗥𝗼𝗯𝗼𝘁 𝗣𝗿𝗼𝗷𝗲𝗰𝘁, our next step was to understand the environment in which it will actually operate.
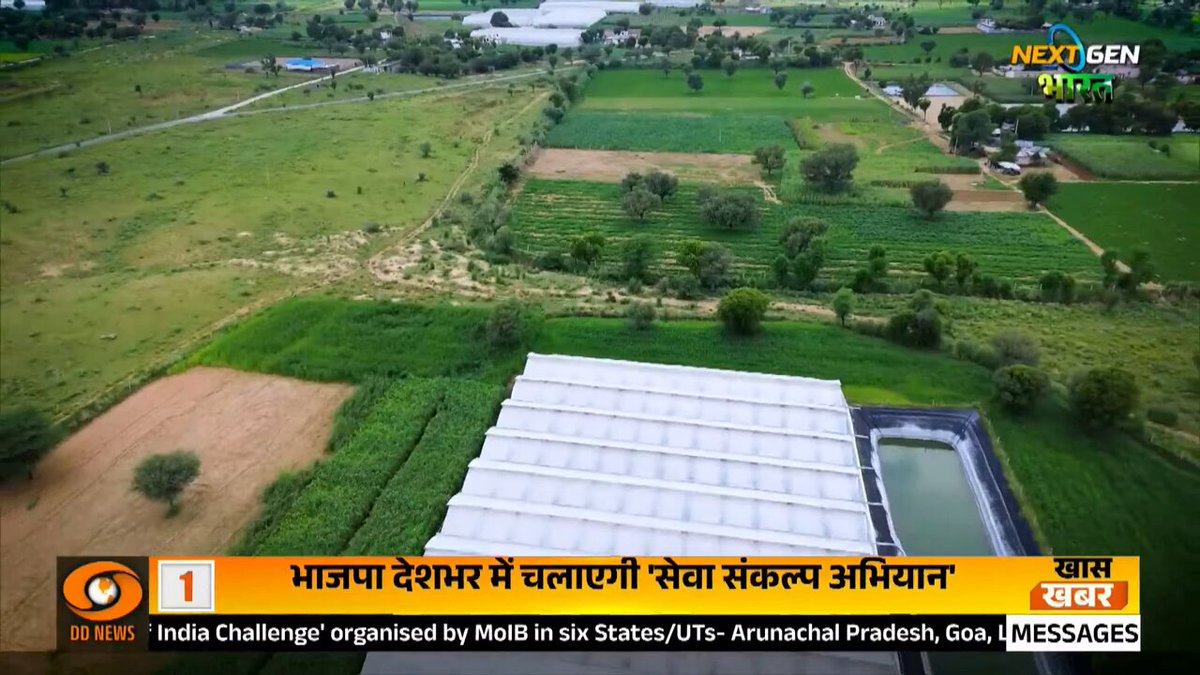
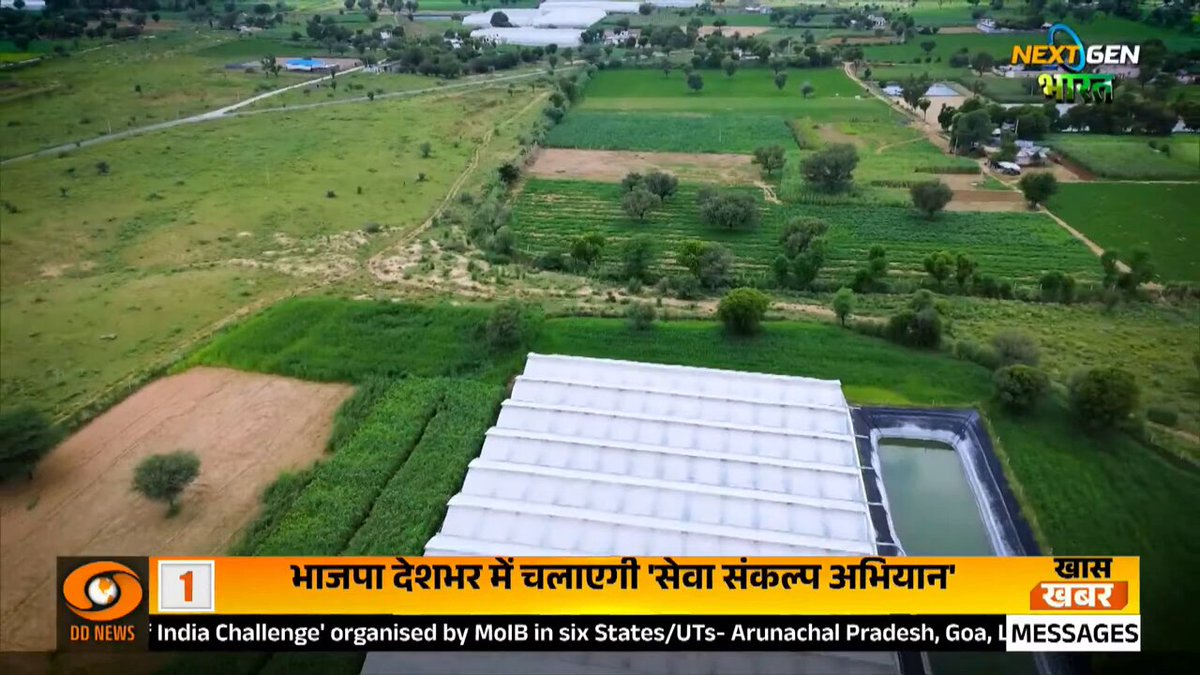
Recently, 𝗧𝗲𝗮𝗺 𝗠𝗮𝗴𝗮𝗱𝗵 𝗚𝗻𝗮𝗻 - Yashwanth Padigam, Avinash Srigiri, Prakash Shaganti & 𝗜, visited a spinach field to study the real-world conditions and challenges involved in autonomous field navigation.
A field is very different from a controlled lab environment.
Crop arrangement, field boundaries, soil conditions, available movement space, and the relationship between crop and non-crop areas all become important when designing a reliable navigation strategy.
Based on our observations, we developed a preliminary 𝗙𝗶𝗲𝗹𝗱 𝗡𝗮𝘃𝗶𝗴𝗮𝘁𝗶𝗼𝗻 & 𝗣𝗮𝘁𝗵 𝗣𝗹𝗮𝗻𝗻𝗶𝗻𝗴 𝗖𝗼𝗻𝗰𝗲𝗽𝘁, translating the physical field environment into a structured movement plan for the robotic system.
𝗢𝗯𝘀𝗲𝗿𝘃𝗲 → 𝗨𝗻𝗱𝗲𝗿𝘀𝘁𝗮𝗻𝗱 → 𝗠𝗮𝗽 → 𝗣𝗹𝗮𝗻 → 𝗕𝘂𝗶𝗹𝗱 → 𝗧𝗲𝘀𝘁 → 𝗥𝗲𝗳𝗶𝗻𝗲.
This field visit was another important step in our journey from 𝗯𝘂𝗶𝗹𝗱𝗶𝗻𝗴 𝗿𝗼𝗯𝗼𝘁𝗶𝗰 𝗰𝗼𝗺𝗽𝗼𝗻𝗲𝗻𝘁𝘀 to 𝗲𝗻𝗴𝗶𝗻𝗲𝗲𝗿𝗶𝗻𝗴 𝗰𝗼𝗺𝗽𝗹𝗲𝘁𝗲, 𝗿𝗲𝗮𝗹-𝘄𝗼𝗿𝗹𝗱 𝗿𝗼𝗯𝗼𝘁𝗶𝗰 𝘀𝘆𝘀𝘁𝗲𝗺𝘀. 🤖🌱
And we're just getting started.
Proud of the progress we're making together at Magadh Gnan Private Limited
#MagadhGnan #AgriculturalRobotics #AgriTech #Robotics #AutonomousRobots #PathPlanning #FieldRobotics #RoboticsEngineering #ComputerVision #AI #DeepTech #Engineering #Innovation #MakeInIndia
9 September 2026 à 10h30
View on LinkedIn →